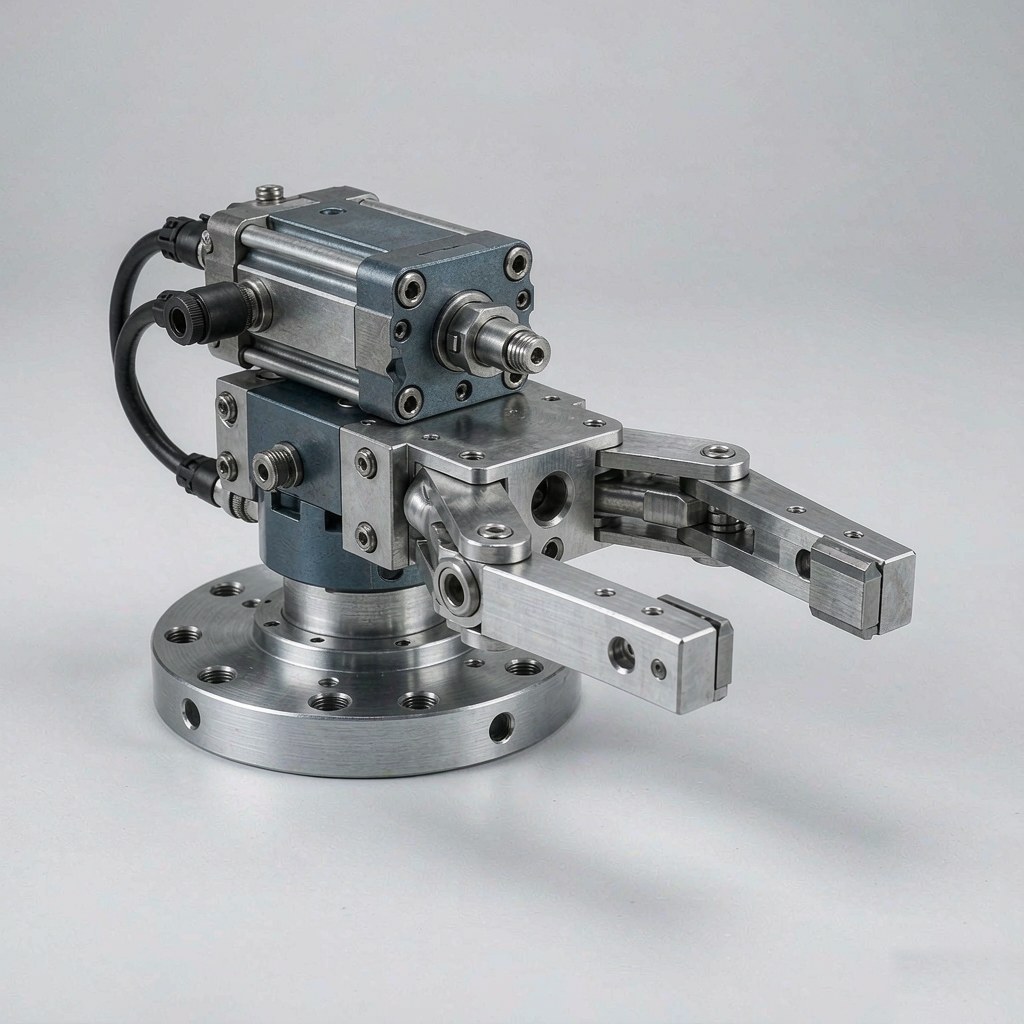
The EF-20 is built to the workpiece geometry and process forces, with a quick-change interface letting one robot swap among multiple tools. Grip force and stroke are adjustable to avoid deforming thin-wall parts.
Features
- Non-contact measurement with no surface damage
- Real-time output linked to sorting and rejection
- Algorithms retrainable per defect category
- Ready to connect with MES and traceability systems
Applications
For machine tending, transfer and robot applications around machine tools.